Questions worth pursuing.
Flight dynamics, terrain interaction, and passive descent. Independent work grounded in models, simulation, and careful interpretation.
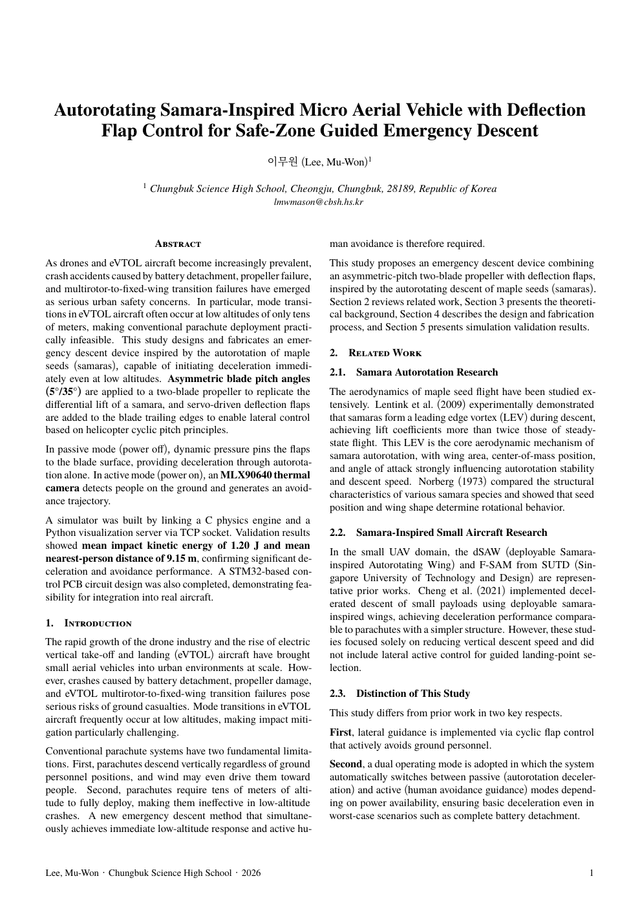
GES — Ground Effect Stabilizer
Onboard-sensor-based feedforward estimation of ground effect over irregular terrain, comparing machine learning and analytical models for multirotor flight.
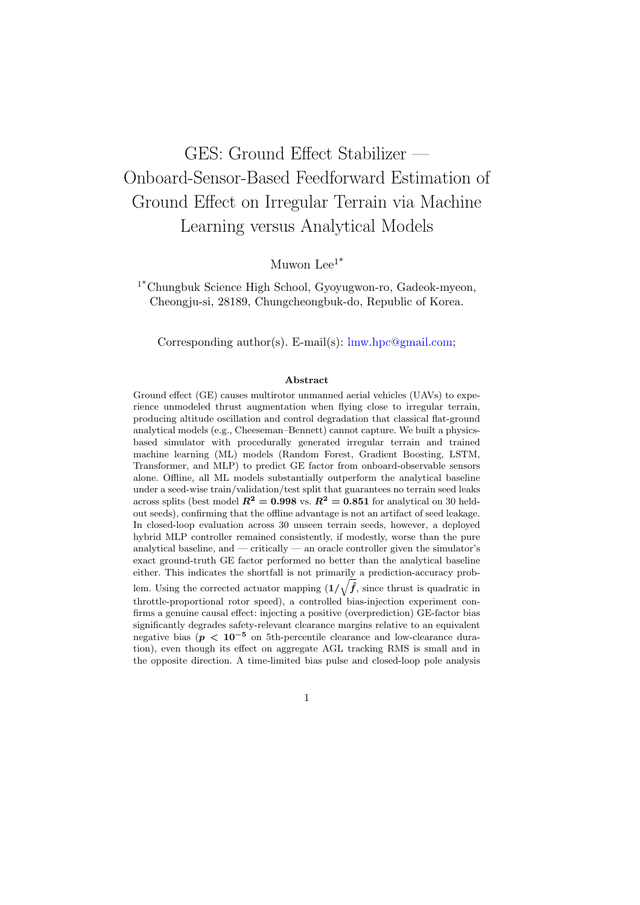
DDF — Drone Drop Finder
Probabilistic drone crash analysis using a C# / .NET rigid-body simulator and a C99 lookup-table library for embedded prediction.
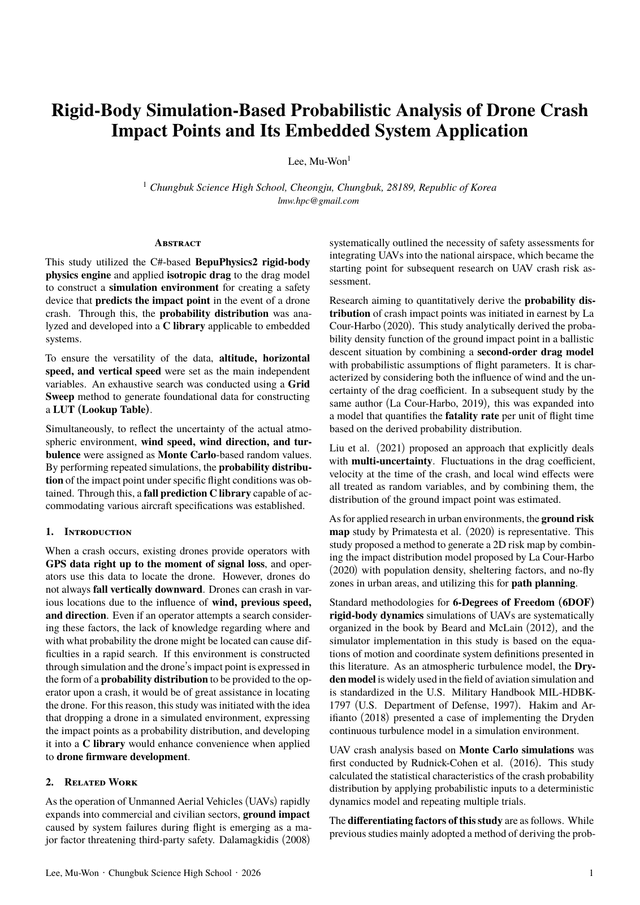
Samara Autorotation Descent Research
Samara-inspired emergency descent with asymmetric blade pitch, cyclic flap guidance, a C/Python simulator, and an STM32 control-circuit design.
IMU Integration & Accumulated Error
C quadrotor simulation comparing Euler, trapezoidal, and Simpson integration under an MPU6050-inspired noise model, with Python Monte Carlo analysis.
FPV LiPo Thermal Runaway Guard
Battery-state estimation and adaptive output-limiting research using a 1RC equivalent circuit, five-state EKF, Arrhenius model, NASA discharge data, and an FPV simulator.
PROJECT NOTES / SCOPE, CONTRIBUTION & ORIGINAL RESOURCES.